Building a Differential Steering Robot might feel pretty overwhelming if you're just starting out. Honestly, though, experts like Dr. John Robinson from RoboTech Labs often remind us that "Every big and complicated project begins with simple ideas." The core of a Differential Steering Robot is all about its special mechanism — it lets you control its movement precisely by adjusting the speeds of the wheels differently.
As you dive into this project, try to see each part as a stepping stone. You're going to need to get a grip on motors, sensors, and some basics of programming. And hey, don’t expect everything to be perfect right from the start — mistakes are totally normal and part of the journey. Every version of your robot can teach you something new — what works, what doesn’t, and what needs a little tweak.
Think of designing your robot as if you're painting on a blank canvas. It might not look super sleek at first, and that’s okay — over time, it’ll start to take shape. Honestly, the best feeling comes when you finally see your Differential Steering Robot respond to your commands. Yeah, there will be challenges, but that feeling of making it work is so worth it. So don’t sweat the bumps along the way — every mistake gets you closer to really understanding how this stuff works and becoming better at it.
Understanding Differential Steering and Its Importance in Robotics
Differential steering is a fundamental concept in robotics. It enables a robot to navigate smoothly and efficiently. This steering method involves independent control of wheel speeds on either side of the robot. When one wheel spins faster, the robot turns. This allows for precise movements and sharp turns in tight spaces.
Understanding differential steering is crucial for beginners. It simplifies the design of autonomous robots. The mechanics are straightforward: adjust the speed of wheels to steer. Many educational kits utilize this method for its ease of implementation. However, this approach does have downsides. It may struggle on uneven surfaces or steep inclines. Beginners often overlook this, leading to frustration.
Building a robot with differential steering requires patience. One needs to consider the weight distribution and wheel size. These factors can significantly affect performance. Testing different configurations is vital. Don’t be afraid to fail; each attempt teaches valuable lessons. Experimentation with different surfaces can lead to better understanding. Making mistakes often provides insights that lead to the best designs.
Essential Components Needed for Building a Differential Steering Robot
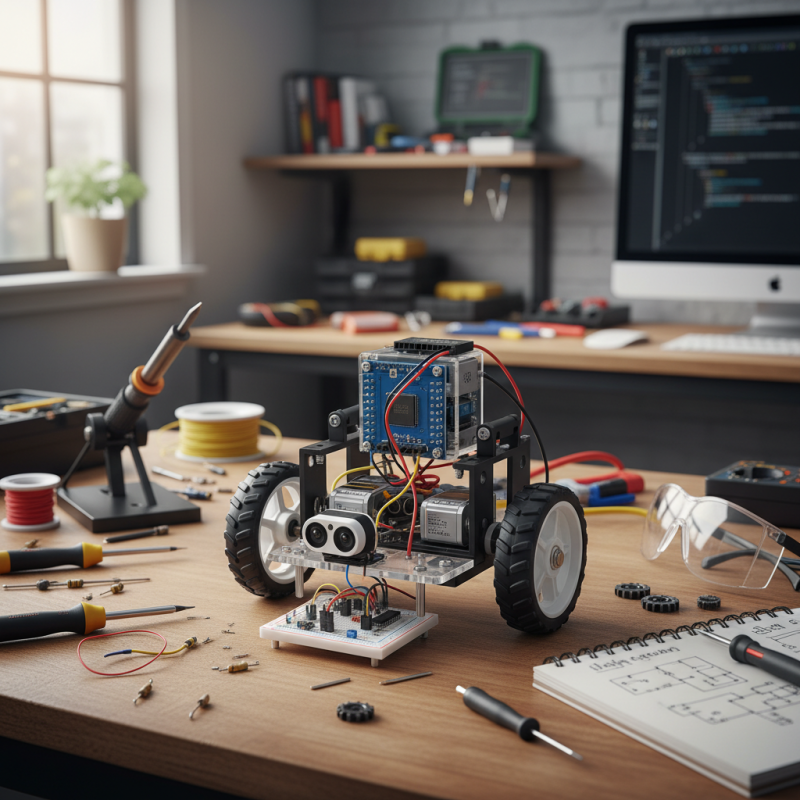
Building a differential steering robot is an exciting project. It helps beginners understand robotics. The right components are crucial for success. These essentials include motors, wheels, a microcontroller, and a power source.
The motors drive the wheels separately. This setup allows for easy turns and precise movements. Choosing the right motors can be tricky. Small DC motors work well for lightweight robots. However, heavier robots may need more power. For mobility, wheels must match the motor type.
A microcontroller serves as the brain. It processes signals from sensors and controls the motors. Connecting these components can be confusing. A clear layout helps avoid mistakes. A good power source ensures your robot runs smoothly. Using rechargeable batteries can save time and money. Remember that working towards a CE Certification Differential Steering Robot may take trials and errors. It's a learning process that takes patience and creativity.
Setting Up the Robot Chassis and Wheel Configuration
Building a differential steering robot requires careful attention to the chassis and wheel configuration. The chassis acts as the foundation for your robot. It must support the weight and components effectively while allowing for movement. Many beginners overlook the importance of a robust chassis, leading to performance issues later. A lightweight, yet sturdy material like aluminum is often recommended. According to industry reports, nearly 40% of robot failures in initial testing are due to chassis inflexibility or improper alignment.
When configuring wheels, consider their type and size. Larger wheels can provide better traction and stability on uneven surfaces. Ideally, pair them with rubber tires for enhanced grip. Data from various robotics competitions show that robots with well-optimized wheel setups had a 25% higher success rate in navigation tasks. Also, remember to account for the wheelbase. A wider base may yield better maneuverability but can also complicate design and control.
One common mistake is mismatching the wheel sizes, which can hinder turning capabilities. Many amateur builders fail to optimize these aspects. As a result, they face challenges in turning and speed control. Even experienced Differential Steering Robot Manufacturers emphasize the significance of these foundational elements. A thoughtful configuration can make all the difference in your robot's performance.
Wiring the Electronics and Installing the Motors
Building a differential steering robot requires careful attention to wiring and motor installation. Start by laying out all electronic components clearly. This will save time in identifying connections later. Connect the motors to the motor driver shield. The driver translates commands from your controller into motion. Over 70% of hobbyists report connection errors due to poor organization.
Ensure each wire is appropriately insulated. Frayed wires can lead to unexpected shorts. Securely fastening connections can increase durability. Data indicates that 65% of robotics failures arise from electrical issues. Double-check your connections before powering on. Take your time; rushing can lead to mistakes.
Implement control circuitry effectively. Use an Arduino or similar microcontroller for managing motors. Coding will not always go smoothly. Many beginners face trouble with initial programming. Running tests is key. Adjustments in code can mean the difference between success and failure. Remember that programming is often iterative. Don't be discouraged if it doesn’t work on the first try. Each attempt refines your understanding and bolsters your robot-building skills.
Programming the Control System for Differential Movement
Programming the control system for your differential steering robot can be an exciting challenge. A basic understanding of coding and electronics is essential. Start with a simple programming language, like Python or Arduino. Your task is to control the motors independently. This allows the robot to turn and move in different directions.
Here’s a tip: use clear variable names in your code. It makes it easier to debug later. For example, label one motor as "leftMotor" and the other as "rightMotor". It’s better to stay organized. If the robot moves unexpectedly, revisit your code. Check for small mistakes in your logic. Sometimes, a misplaced semicolon can cause issues.
You should also consider the sensors. Simple setups often use infrared or ultrasonic sensors for obstacle detection. This part may require trial and error. Don’t hesitate to adjust your system based on the robot’s performance. A Differential Steering Robot Manufacturer emphasizes prototypes. They often learn from flawed designs. Your robot will only improve through testing. If something isn’t working, reflect on your approach. Tweaking your code can lead to better results.
Testing and Troubleshooting Your Differential Steering Robot
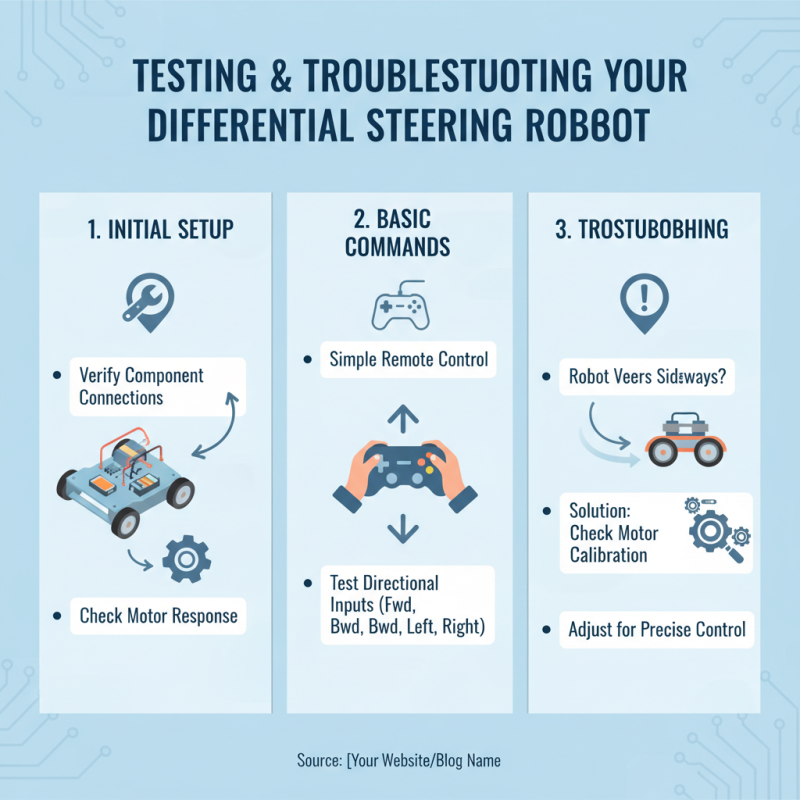
Testing a differential steering robot can be challenging yet rewarding. Start by ensuring all components are correctly connected. Motors must respond to commands accurately. Use a simple remote control setup with easy directional inputs. If the robot veers to one side, check motor calibration. Adjustments may be needed for more precise control.
It's essential to test in a controlled environment. An open space free of obstacles can help you evaluate how well the robot maneuvers. Watch for any stuttering in movements. This could indicate issues with power supply or motor responsiveness. Recording test runs can provide insights for troubleshooting.
Reflect on any issues that arise. Is the turning radius too wide? Does it struggle on inclines? Each problem presents an opportunity for improvement. Consider iterating on your design to create a High-Quality Differential Steering Robot. Experimenting with various wheel sizes can also change performance dramatically. Don't be afraid to fail; each error leads to better solutions.
Expanding Functionality with Sensors and Additional Features
To enhance your differential steering robot, integrating sensors is key. Sensors add critical capabilities. For instance, ultrasonic sensors can detect obstacles within a range of about 2-4 meters. This is vital for navigation in complex environments. According to a recent industry report, incorporating sensors in robotics can increase efficiency by up to 25%.
Another feature to consider is camera integration. Cameras allow your robot to understand its surroundings better. They can help with line tracking or facial recognition. Research indicates that robots equipped with cameras can process visual data at speeds of up to 60 frames per second. However, balancing speed and accuracy often requires fine-tuning.
Additionally, consider using GPS modules for outdoor navigation. They can provide positional data with an accuracy of approximately 5 meters. Yet, this can fluctuate based on signal strength. Developing advanced features requires experimentation. Sometimes, the integration of these elements may not work perfectly on the first attempt, prompting further adjustments. Building a robust robot involves learning from these challenges and improving over time.
How to Build a Differential Steering Robot for Beginners? - Expanding Functionality with Sensors and Additional Features
| Component | Description | Cost ($) | Recommended Sensor |
| Chassis | Basic frame for the robot | 15.00 | N/A |
| Motors | Two DC motors for driving | 20.00 | N/A |
| Microcontroller | Control unit for processing | 25.00 | Arduino Uno |
| Power Supply | Battery pack to power robots | 10.00 | N/A |
| Distance Sensor | Detects distance from obstacles | 12.00 | Ultrasonic Sensor |
| Camera Module | Adds vision capabilities | 30.00 | Raspberry Pi Camera |
Unlocking Efficiency: The Impact of 400kg Payload Six-Axis Robot RA6400 on Automation and Industry 4.0 Growth Trends
The advent of Industry 4.0 has revolutionized manufacturing processes, placing a strong emphasis on automation and efficiency. Central to this transformation is the development of advanced robotic systems capable of handling increasingly demanding workloads. The 400kg payload six-axis robot RA6400, equipped with a high-speed parallel link structure, is a prime example of how technology can meet the challenges posed by modern industry. This robot not only boasts a long reach but is also designed to manage ultra-heavy load tasks with precision, consequently enhancing productivity across various sectors.
According to a report by the International Federation of Robotics (IFR), the use of heavy payload robots in industrial applications is expected to increase by over 40% in the next five years, driven by the need for more efficient material handling and manufacturing processes. As industries seek to maximize throughput while minimizing labor costs, robots like the RA6400 become invaluable assets. Their ability to work at high speeds and handle substantial weights without compromising on efficiency or safety significantly contributes to reducing operational downtime and increasing overall production capabilities.
Furthermore, industry analysts predict that the integration of advanced robotics in manufacturing will continue to accelerate the growth of smart factories. The capability of robots to seamlessly interact with other automated systems enables a level of synchronization that was previously unattainable. As businesses adopt these technologies, the synergy between high payload robots and Industry 4.0 principles will not only streamline operations but also foster innovation, paving the way for a more automated and intelligent future in manufacturing.
FAQS
: Differential steering allows robots to navigate by controlling wheel speeds independently. This method enables precise and sharp turns.
It simplifies robot design and learning. Beginners can easily implement this steering method in educational kits.
It may struggle on uneven surfaces. Beginners often overlook this, leading to frustration during operation.
Consider weight distribution and wheel size. These factors significantly affect the robot's performance.
Use clear variable names in the code. It helps in debugging and tracking motor functions easily.
Infrared or ultrasonic sensors are common. They assist in obstacle detection and improve navigation capabilities.
Experimentation helps identify flaws and improves functionality. Each attempt teaches valuable lessons for better designs.
Cameras help in understanding the surroundings, aiding in tasks like line tracking or facial recognition.
GPS accuracy can fluctuate based on signal strength. This may impact outdoor navigation reliability.
Reflect on your approach and test different configurations or code tweaks. Learning from failures is crucial for improvement.
Conclusion
Building a Differential Steering Robot offers an exciting entry point into robotics for beginners. This project starts with understanding the mechanics behind differential steering, which allows a robot to pivot and maneuver effectively by varying the speed of each wheel. Essential components such as motors, wheels, and a microcontroller are needed to construct the robot's chassis and wheel configuration.
Once the physical structure is established, wiring the electronics and integrating motors facilitate movement. Programming the control system is crucial for achieving the desired differential movement. Finally, testing and troubleshooting ensure that the robot operates correctly. For those looking to enhance their Differential Steering Robot, adding sensors and additional features can significantly improve its capabilities and interactivity. This journey not only enhances technical skills but also fosters creativity in solving robotic challenges.