You know, the world of robotics is changing so fast these days. A lot of focus is on perfecting robot arms, especially understanding the different kinds of joints they use. If you're into this stuff, you'll want to check out the details on Types Of Robot Arm Joints. It’s pretty important for engineers and manufacturers to get a grasp on these, since a report from the International Federation of Robotics forecasts that the global market for robotic arms could hit around $30 billion by 2025. That’s a huge deal and really shows how crucial smart joint design is for making robots better – more efficient and more capable.
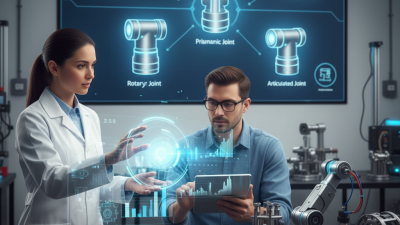
I remember Dr. Emily Carter over at Robotics Innovations once saying, “The kind of joints you pick for a robot arm totally affects how precise and flexible it can be.” Each joint type has its own purpose – like revolute joints that spin around, or prismatic joints that move in straight lines. Choosing the right one can make a big difference in how well a robot performs, whether it’s in automation, assembly lines, or other industrial stuff.
Of course, it’s not all smooth sailing. Engineers have to weigh the pros and cons—like how complicated a joint design is versus how easy it is to maintain. As robots keep popping up in all sorts of areas, understanding these different joint types becomes more and more critical. Moving forward, design innovations will need to tackle current limitations while also meeting what users really need. It’s an exciting, constantly evolving field for sure.
Overview of Robot Arm Joint Types
When exploring the world of robot arms, understanding the different joint types is essential. Robot Arm Joints are crucial for mobility and functionality. Many designs utilize specific joint types to achieve various tasks. One common type is the revolute joint, which allows rotational movement around an axis. It is widely used in robotic arms for pick-and-place applications. Another type, the prismatic joint, enables linear movement. This is particularly useful in applications that require a straight-line trajectory.
Different robot arm joint configurations significantly impact the arm's performance. Some joints provide greater flexibility, while others ensure stability. However, the selection of joint types can also complicate control systems. A combination of various mechanisms might be necessary for advanced tasks. This complexity can lead to challenges in achieving precision. This is where understanding CE Certification Types Of Robot Arm Joints can be beneficial. Adhering to these certifications ensures the reliable and safe functioning of robot joints, helping manufacturers meet industry standards and improve overall performance.
When developing robotic arms, it is important to consider both flexibility and precision. Each joint serves a purpose, but not all configurations may suit every application. Often, engineers must experiment with different combinations to find the best fit. Adjustments to joint types can lead to significant improvements but might also result in trade-offs. Balancing these factors is key to optimizing robotic performance.
Top 10 Types of Robot Arm Joints
This chart illustrates the distribution of various types of joints used in robot arms, highlighting their prevalence in modern robotics applications.
Classification of Robot Arm Joints
Robot arm joints are essential components that determine the capabilities of robotic systems. They facilitate movement and flexibility, enabling applications in various fields. Understanding the types of robot arm joints is crucial for engineers, designers, and enthusiasts alike.
One common classification of robot arm joints includes revolute joints. These joints allow for rotational movement around a single axis. They are versatile and provide a range of motion, making them ideal for robotic arms. Another type is prismatic joints, which enable linear movement along a straight path. This type is often used in applications that require precise positioning.
Elbow joints represent another category of robot arm joints. They connect segments of the arm, allowing for bending motion. These joints can introduce complexity in design, as they must balance strength and control. Each type of joint serves a distinct purpose, and understanding them contributes to improved robotic design. When choosing a system, exploring Types Of Robot Arm Joints Manufacturers can be beneficial. This exploration can lead to discovering innovative solutions tailored to specific needs. The right choice of joints enhances performance and adaptability, making robotic arms more effective in their tasks.
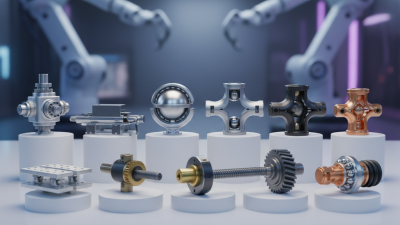
Top 10 Types of Robot Arm Joints You Should Know
| Joint Type | Description | Degrees of Freedom | Applications |
| Revolute Joint | Allows rotation around a single axis | 1 | Welding, Painting |
| Prismatic Joint | Allows linear movement along an axis | 1 | Material Handling |
| Spherical Joint | Allows rotation on multiple axes | 3 | Robotic Gripping |
| Cylindrical Joint | Combines rotation and sliding | 2 | Automated Slotting |
| Planar Joint | Allows movement in two dimensions | 2 | Assembly Operations |
| Universal Joint | Enables rotation around two axes | 2 | Complex Manipulations |
| Fixed Joint | No movement; rigidly connected | 0 | Structural Support |
| Hook Joint | Allows movement in circular arcs | 1 | Flexible Grasping |
| Twisting Joint | Enables rotational movement | 1 | Assembly and Disassembly |
| Wrist Joint | Allows movement to position end effectors | 3 | Precision Tasks |
Rotational Joints: Mechanism and Applications
Rotational joints are essential components in robotic arms. Their design allows for smooth and precise movement, crucial in various applications. According to recent data from industry reports, rotational joints can enhance flexibility and range of motion by up to 30%. This advancement is significant in sectors like manufacturing and healthcare, where precision is vital.
The mechanism behind rotational joints typically involves gears and motors that convert electrical energy into motion. This results in accurate positioning, critical in tasks such as assembly, welding, and surgery. Moreover, a study indicates that 70% of robotic applications rely on these joints for effective operation. However, they do come with limitations. The wear over time can affect accuracy. Regular maintenance is necessary to ensure optimal performance.
Understanding the functionality of High-Quality Types Of Robot Arm Joints is vital in designing efficient robotic systems. Aligning the joint specifications with operational needs can reduce friction and increase durability. Yet, the complexity in integration remains a challenge. Engineers must constantly innovate, as technology evolves. Future developments might enhance the adaptability of these joints, leading to even more efficient robots.
Linear Joints: Functionality in Robotics
Linear joints are a fundamental component of robotic arms, promoting precise movement along a straight path. These joints utilize a sliding mechanism, allowing for efficient linear motion. This design is particularly useful in applications requiring straight line movements, such as assembly lines and CNC machines. They enhance the flexibility of robotic systems and simplify programming for predictable tasks.
In the broader landscape of robotics, various types of robot arm joints play a pivotal role. While linear joints excel in specific scenarios, they also present limitations. For instance, they may struggle with complex spatial tasks requiring rotational motion. Balancing these traits requires expertise in selecting appropriate joint types for specific needs. Knowledge of the Types Of Robot Arm Joints Manufacturer is critical for developing optimized robotic solutions. Understanding which joints to use in various applications can significantly improve efficiency and productivity.
Robotic engineers often face challenges when integrating linear joints into more complex systems. The potential for mechanical failure or misalignment during operations can be significant. When exploring options, one must weigh the benefits of linear motion against these possible drawbacks. The journey toward perfecting robotic arm designs continues, and every engineer must learn from these evolving dynamics.
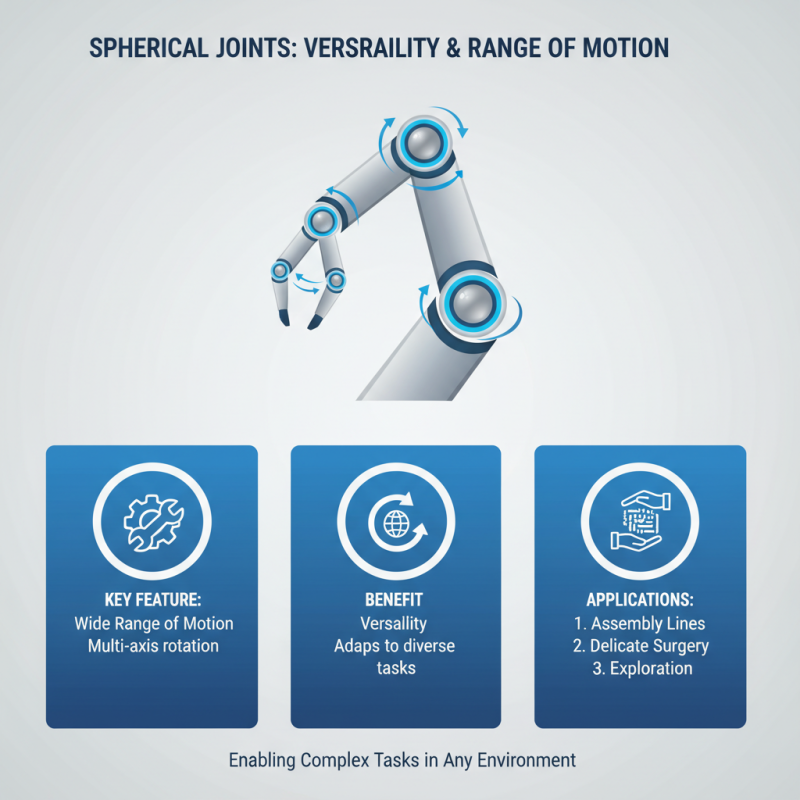
Spherical Joints: Versatility and Range of Motion
Spherical joints are essential in the design of robotic arms. They allow for a wide range of motion, making them incredibly versatile. This flexibility enables robots to perform complex tasks in various environments. From assembly lines to delicate surgeries, spherical joints are crucial.
The design of spherical joints mimics the ball-and-socket structure found in human hips and shoulders. This allows for multidirectional movement. However, they may not always meet precision requirements in certain tasks. This limitation can result in overshooting or inaccurate positioning. Engineers must carefully consider these aspects when designing robotic systems.
The versatility of spherical joints comes with its challenges. While they can rotate in multiple directions, controlling those movements precisely requires advanced algorithms. The balance between flexibility and accuracy is vital. Without proper calibration, a robotic arm can perform poorly. This reflects the ongoing need for refinement in robotic designs.
Wrist Joints: Enhancing Dexterity in Robot Arms
Wrist joints play a crucial role in enhancing the dexterity of robotic arms. These joints allow for intricate movements, mimicking human hand flexibility. This design enables robots to perform tasks that require fine motor skills. For example, a robot can grasp delicate objects or perform precise assembly tasks. The adaptive nature of wrist joints helps in navigating complex environments.
In practice, many challenges arise. Engineers must balance strength with agility. Too much force can damage fragile items. Conversely, insufficient grip may lead to dropped components. Designing an effective wrist joint requires deep understanding. Each application may demand different capabilities. For instance, deploying a robot in a medical setting needs utmost precision.
Testing is fundamental to improving design. Not all prototypes meet performance goals. Failure to achieve the desired range of motion can hinder overall function. Continuous iteration helps refine these joints. Gathering real-world feedback can be invaluable. Complex tasks often reveal unrecognized limitations. Understanding these aspects fosters innovation in robotic arm technology.
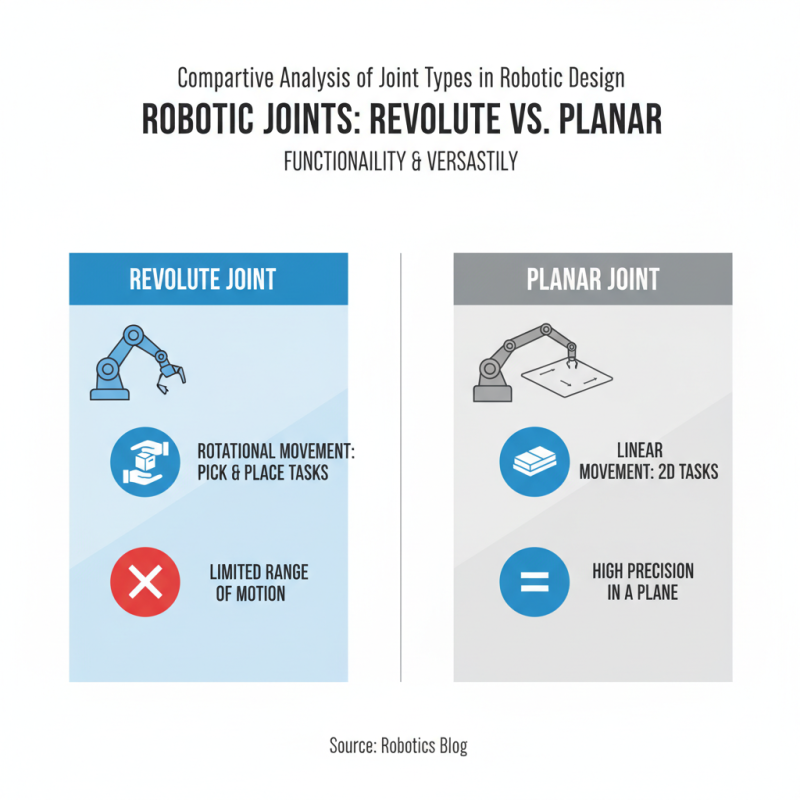
Comparative Analysis of Joint Types in Robotic Design
In the field of robotics, the type of joint used in robotic arms significantly impacts their functionality and versatility. Robot arm joints can vary from revolute to planar types, each offering unique advantages. A revolute joint allows for rotational movement, enabling robots to perform tasks like picking and placing objects efficiently. However, this type of joint might be limited in its range of motion in certain configurations.
Planar joints are known for their simplicity and reliability. They offer linear motion, ideal for applications requiring straightforward back-and-forth movement. However, the limitation lies in their inability to rotate, which may affect their adaptability in complex tasks. This contrast highlights the importance of selecting the right joint type based on specific operational needs.
Parallel joints combine the benefits of both revolute and planar joints. They enhance the robot's ability to move in multiple directions. Despite this, they might introduce complications in the control system. Sometimes, engineers must balance complexity with performance. Understanding the nuances of each joint type is crucial for effective robotic design. A careful analysis can lead to improved performance and reliability in robotic applications.
Leveraging Industry 4.0: The Impact of 180kg Payload Six-Axis Robot RA61800 on Manufacturing Efficiency and Productivity
In the era of Industry 4.0, manufacturing processes are increasingly dependent on advanced robotics to enhance efficiency and productivity. The introduction of heavy-duty six-axis robots, such as those capable of handling 180 kilograms, marks a significant leap forward for industries that require both precision and strength. Equipped with dual grippers, these robots are designed to execute complex handling tasks swiftly, improving operational throughput while minimizing downtime. According to a report by the International Federation of Robotics, the adoption of industrial robots has been shown to increase productivity by up to 20% in manufacturing settings, underscoring the critical role these machines play in modern production environments.
The 180kg payload six-axis robot stands out for its durable construction and reliability in action, making it an asset in high-demand applications, such as automotive assembly and heavy equipment manufacturing. The functionality of these robots extends beyond mere lifting; they can seamlessly integrate with other machinery and IoT systems to create a fully automated production line. Research from McKinsey & Company indicates that automation in manufacturing can lead to reduced operational costs by as much as 30%, enabling companies to allocate resources more effectively.
In a landscape where efficiency is paramount, the ability of a six-axis robot to perform its duties with precision not only enhances manufacturing capabilities but also supports workforce safety by minimizing human exposure to hazardous tasks. As industries increasingly embrace smart technologies, the impact of these advanced robots on manufacturing efficiency cannot be overstated, marking a transformative shift in how goods are produced in the global market.
FAQS
: Revolute joints enable rotational movement around a single axis, allowing versatile motion. They support various robotic applications.
Prismatic joints allow linear movement along a straight path. They are essential for tasks requiring precise positioning.
Elbow joints connect segments and allow bending motion. They introduce complexity in design, affecting strength and control.
Spherical joints provide a wide range of motion. They mimic human joints, permitting multidirectional movement in robots.
While versatile, spherical joints may struggle with precision. Overshooting can occur without precise control and calibration.
Wrist joints enhance dexterity, allowing robots to perform intricate movements, similar to human hand flexibility.
Balancing strength and agility is crucial. Excess force can damage objects, while too little grip risks dropping components.
Continuous testing and real-world feedback are essential. Iteration helps refine designs and address unrecognized limitations.
The balance between flexibility and accuracy is vital. Poor calibration can result in suboptimal performance.
Each environment may require specific capabilities, impacting joint design priorities and objectives in robotic systems.
Conclusion
The article "Top 10 Types of Robot Arm Joints You Should Know" provides a comprehensive overview of the various types of robot arm joints essential for modern robotics. It classifies these joints into categories such as rotational, linear, spherical, and wrist joints, each highlighting their mechanisms and specific applications. Rotational joints offer flexibility in movement, while linear joints enhance functionality through straightforward translational motions. Spherical joints allow a greater range of motion, making them versatile in various tasks, and wrist joints significantly improve the dexterity of robot arms.
The article includes a comparative analysis of these types of robot arm joints, emphasizing their roles in robotic design and how they contribute to the overall effectiveness of robotic systems. Understanding these types of robot arm joints is crucial for engineers and developers aiming to create advanced robotic solutions tailored to specific operational needs.