In the fast-changing world of robotics, understanding the different types of joints really matters. Dr. Emily Johnson, who's a pretty well-known expert in robotic engineering at RoboTech Innovations, mentions, "The kind of joints you pick affects how flexible a robot is and what it can do." So, it’s clear that selecting the right joint for the job is super important.
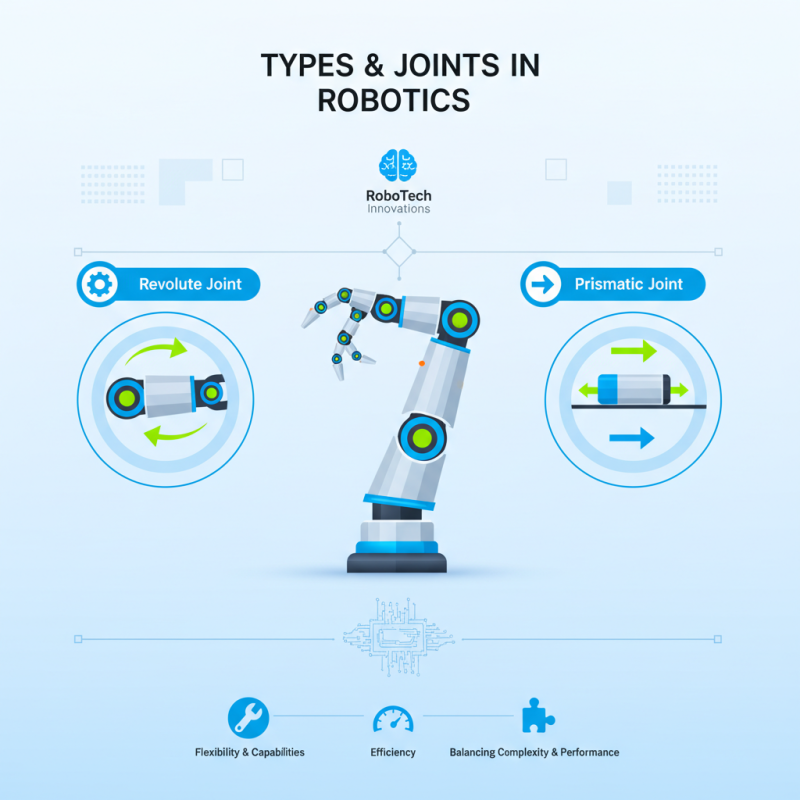
There are various joint types, like revolute and prismatic joints, and they basically determine how robots move and interact with their surroundings. For instance, revolute joints let parts rotate, while prismatic joints are all about sliding back and forth. Picking the right joints makes a robot work more smoothly and efficiently. That said, engineers often have a tricky balancing act — trying to keep things simple without sacrificing performance.
And, of course, not every joint design fits every situation. Some might limit how far a robot can stretch or might bump up manufacturing costs too much. As the industry keeps advancing, there's a big need for smarter, more innovative joint solutions. Talking about the "Types Of Joints in Robotics" really shines a light on both what’s possible and what the limitations are when designing robots. Tackling these challenges head-on can really push things forward and help create robots that are just, well, better at what they do.
Overview of Robotics Joints and Their Importance
Robotic Joints are crucial for movement and flexibility in robotic systems. They enable robots to interact with their environment effectively. The importance of these joints is evident in various applications from manufacturing to healthcare. A report by the International Federation of Robotics states that the industrial robot market is projected to grow by 10% annually. This growth emphasizes the need for sophisticated joint designs.
Joints can be classified into several types, including revolute, prismatic, and spherical. Each type serves specific functions, allowing for different ranges of motion. For instance, revolute joints rotate around a fixed axis, while prismatic joints allow linear motion. These distinctions impact a robot's performance. Some researchers argue that better joint designs can enhance a robot's functionality and reduce operational costs.
Tip: When selecting robotic joints, consider the application requirements. Different tasks may need varying degrees of flexibility or strength. Evaluate the robot's expected load and movement complexity to choose the right joint type. Always factor in maintenance needs, as more complex joints may require more frequent servicing. Exploring innovative joint designs can drive future advancements in robotics. Exploring emerging technologies in joint design can yield substantial benefits and increase flexibility in robotic applications. This exploration could also highlight areas for potential improvement and innovation in robotic systems.
Types of Joints in Robotics
This chart presents the various types of joints used in robotics and the number of applications for each type. Revolute joints are the most commonly used, followed by prismatic and spherical joints, illustrating their significance in robotic design.
Classification of Joints: Revolute, Prismatic, and More
In robotics, joints play a critical role in determining motion and functionality. Major classifications include revolute joints, prismatic joints, and more. Revolute joints allow rotational movement around a single axis. They are essential for robotic arms, enabling precise positioning and flexibility. According to a report from MarketsandMarkets, the market for revolute joints is expected to grow significantly, driven by advancements in automation technology.
Prismatic joints, on the other hand, facilitate linear motion. They enable robots to extend and retract arms or components, providing versatility in various applications. For instance, the material handling industry increasingly relies on prismatic joints for efficient movement of goods. However, prismatic joints may face challenges with alignment and wear over time. A study published in IEEE Transactions highlighted the importance of regular maintenance and calibration to ensure performance.
Other joint types include spherical and screw joints, which serve specialized functions. Each joint type has its own strengths and weaknesses. Despite advances, engineers continually seek improvements. This ongoing quest reflects the complexities involved in robotic design, where balancing efficiency and precision is a constant challenge. Understanding these classifications is crucial for future developments in robotics.
Understanding Revolute Joints: Function and Applications
Revolute joints are key components in robotics, allowing for rotational movement around a single axis. These joints mimic the way human joints operate, enabling flexibility and articulation in robot designs. Commonly seen in robotic arms, they provide precise control over movements, making them essential for tasks like assembly and welding. The simplicity of the revolute joint also contributes to its widespread use in various robotic applications.
In practical terms, revolute joints consist of two linked components, one stationary and the other rotating. They can be designed to accommodate a range of angles, enhancing a robot's ability to navigate complex environments. However, integrating these joints isn't always straightforward. Factors such as weight distribution and the range of motion can complicate their implementation. Designers may need to consider trade-offs between flexibility and strength, impacting overall performance.
Despite these challenges, revolute joints remain a cornerstone of robotic engineering, embodying both the potential and limitations of machine mobility.
Exploring Prismatic Joints: Linear Movement in Robotics
Prismatic joints are essential in robotics, allowing for linear movement. These joints create motion in a straight line, vital for robotic arms and other mechanisms. Often, prismatic joints resemble a sliding mechanism, facilitating smooth transitions. Their design typically involves a slider fitting inside a guiding structure. The simplicity of their function makes them indispensable in various applications.
When working with prismatic joints, ensure proper alignment. Misalignment can lead to friction, affecting performance. Regular maintenance helps maintain efficiency. Be mindful of the weight and load capacity. Overloading can lead to mechanical failure, compromising safety. Always follow the manufacturer’s guidelines for assembly and operation.
Consider testing the joints for smooth movement regularly. A joint that sticks might indicate wear or damage. Small adjustments can improve performance significantly. Understanding the CE Certification Types of Joints in Robotics is crucial. Knowledge of these aspects fosters better design and longevity in robotic systems.
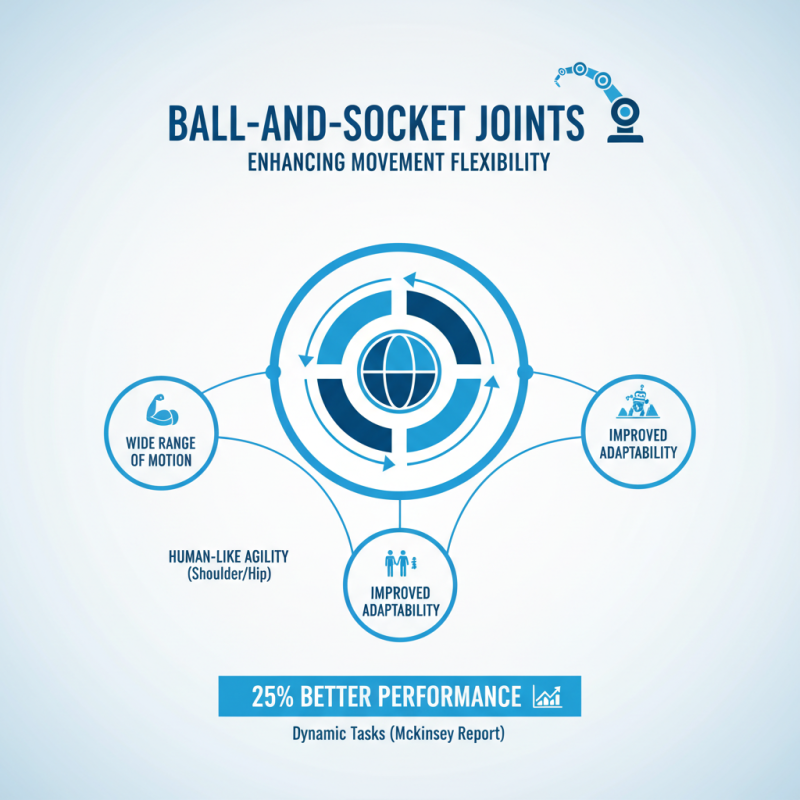
Ball-and-Socket Joints: Enhancing Movement Flexibility
Ball-and-socket joints are crucial in robotics. They allow for a wide range of motion, similar to human shoulder and hip joints. This flexibility improves the robot's adaptability in various environments. According to a report by McKinsey, robots with enhanced joint designs show 25% better performance in dynamic tasks.
The design of these joints makes movements more fluid, enabling tasks like picking and placing items with precision. Yet, challenges remain. The complexity of ball-and-socket joints can lead to increased wear and maintenance costs. A study published in IEEE Transactions indicates that approximately 15% of robotics failures stem from joint malfunctions.
Moreover, integrating ball-and-socket joints in robotics requires careful calibration. Engineers must account for weight and balance. This complexity demands a deeper understanding of mechanics from robotics manufacturers. As robotic applications grow, the need for durable and reliable joints becomes more pressing. The importance of effective joint design cannot be overstated. It directly affects the efficiency and lifespan of robotic systems in real-world applications.
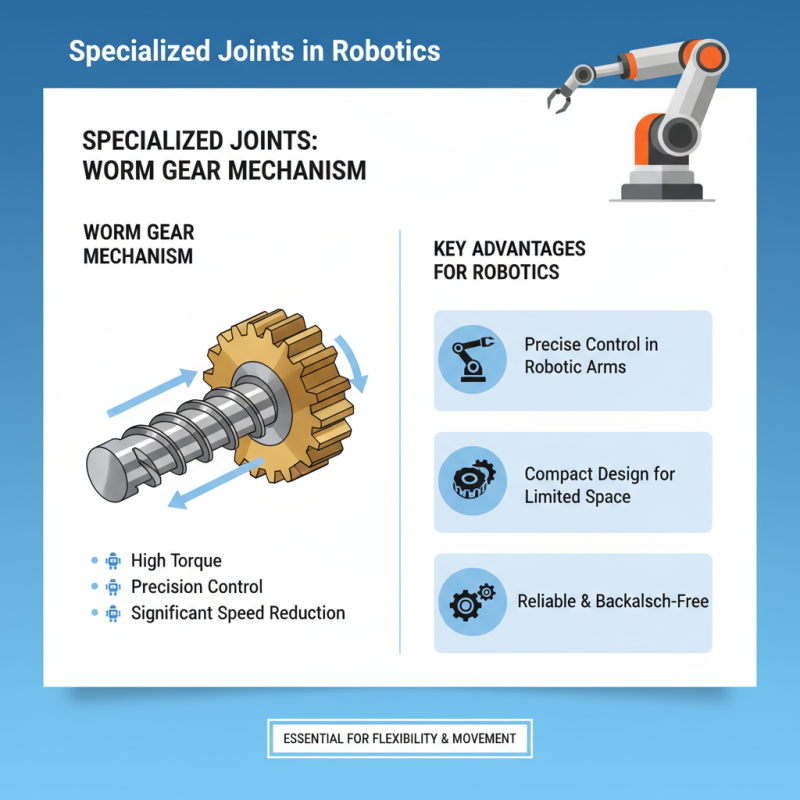
Specialized Joints: Worm Gear and Differential Mechanisms
In robotics, joints are crucial for flexibility and movement. Among various types, specialized joints like worm gears and differential mechanisms stand out. Worm gears consist of a screw-shaped gear that turns a gear wheel, providing high torque and precision. This unique design allows for significant speed reduction, essential for precise control in robotic arms. The compact nature of worm gears makes them suitable for limited spaces in robotic systems.
Differential mechanisms, on the other hand, enable varying movement speeds between output shafts. They allow one wheel to rotate faster than another, crucial in Mobile Robotics. Understanding the function of these joints can truly enhance robotic design. However, the implementation of these mechanisms often presents challenges. Engineers must consider weight, power consumption, and maintenance. These factors can affect the overall reliability of robotic systems.
While both joints offer specific advantages, they also come with drawbacks. Worm gears can be less efficient due to friction. Differential mechanisms can be complicated to design and tune. A careful balance is required. Exploring the Types Of Joints Robotics Manufacturers use can provide insights into optimizing robotic capabilities. This knowledge forms the foundation of effective robotic engineering.
Factors Influencing Joint Selection in Robotic Design
In robotic design, several factors influence the selection of joints, each affecting performance and application. One key factor is the range of motion. For example, a robot arm designed for welding requires precise rotational joints to reach various angles. According to a recent industry report, over 40% of robotic failures stem from inadequate joint selection. This highlights the necessity of understanding various joint types.
Another crucial aspect is load capacity. Robots lifting heavy items need robust joints that can withstand significant weight. Studies indicate that robots with reinforced joints experience up to 30% less wear over time, enhancing longevity. Additionally, the choice of materials plays a pivotal role in joint durability. High-quality types of joints in robotics often employ advanced alloys or composites to maximize strength while minimizing weight.
Finally, environmental conditions cannot be overlooked. Robots operating outdoors may require joints resistant to dust and moisture. The adaptability of joints can lead to a considerable reduction in maintenance costs. However, selecting the right joint is often a balancing act. Many engineers report challenges in achieving the optimum combination of flexibility and rigidity, underscoring the complexity of joint selection in robotics.
Types of Joints in Robotics - Factors Influencing Joint Selection in Robotic Design
| Joint Type | Degrees of Freedom | Applications | Material Considerations | Cost |
| Revolute Joint | 1 | Robotic arms, industrial robots | Aluminum, steel | Medium |
| Prismatic Joint | 1 | Linear actuators, conveyor systems | Plastic, steel | Low |
| Spherical Joint | 3 | Humanoid robots, multi-axis robots | Titanium, carbon fiber | High |
| Cylindrical Joint | 2 | Industrial automation, robotic arms | Aluminum, composites | Medium |
| Planar Joint | 2 | Specialized robots, machine tools | Aluminum, plastic | Low |
FAQS
: Worm gears provide high torque and precision. They allow significant speed reduction. This is crucial for robotic arm control.
Differential mechanisms enable varying speeds between output shafts. This allows one wheel to rotate faster than another.
Key factors include range of motion, load capacity, and environmental conditions. Each affects performance and application significantly.
Robots for specific tasks need precise joints. For instance, a welding robot requires rotational joints for various angles.
Robots lifting heavy items need robust joints. Reinforced joints can lead to less wear and longer service life.
High-quality robotic joints often use advanced alloys or composites. These materials maximize strength while reducing weight.
Joints that resist dust and moisture can lower maintenance costs. They are essential for robots operating in outdoor conditions.
Yes, achieving the right balance of flexibility and rigidity can be complicated. Engineers face various challenges during this process.
Worm gears can experience friction, reducing their overall efficiency. This is an important consideration in robotic design.
Engineers must account for weight, power consumption, and maintenance. These factors can greatly impact robotic reliability.
Conclusion
The article "Types of Joints in Robotics What You Need to Know" provides a comprehensive overview of the various types of joints used in robotic systems and their significance in enhancing functionality and movement. It classifies joints into several categories, including revolute, prismatic, and specialized types like ball-and-socket joints, worm gears, and differential mechanisms. Each type serves distinct purposes, with revolute joints allowing rotational movement and prismatic joints enabling linear motion.
Understanding the different types of joints in robotics is crucial for optimizing design and functionality. Factors influencing joint selection include the desired range of motion, load capacity, and application-specific requirements. This knowledge is essential for engineers and designers to create effective robotic solutions that meet specific operational needs.